jaccen/Awesome-Gaussian-Skills ↗★ 161
awesome-gaussian-skills
3D Spatial Intelligence Open-Source Toolbox — 900 methods, 15 skills, MCP Server, SplatVerse Studio 适合从事3D高斯泼溅(3DGS)研究、需要检索文献和集成相关工作流的科研人员。
インストール
npx -p @deepseek-ai/dsh dsh plugin --profile web add github:jaccen/Awesome-Gaussian-Skillsドキュメント
README 全文を読む ↗
Awesome Gaussian Skills
The Most Comprehensive 3D Gaussian Splatting Catalog — 900 methods, 23 Categories, Interactive Explorer
You shouldn't search 20 repos for 3DGS papers. This is the only one you need.




Why This Repo?
Other awesome lists give you paper titles. We give you paper titles + an AI toolkit that makes you faster.
| What You Need | Other Lists | This Repo |
|---|---|---|
| Browse papers | Static markdown table | Interactive explorer: search, filter, sort |
| Compare methods | Open 2 papers side by side | 10+ dimension auto-comparison |
| Avoid code bugs | Discover after submission | 104 known bug pattern detection |
| Design experiments | Guess baselines & ablations | Venue-tailored experiment plan |
| NeRF → 3DGS | Trial-and-error porting | Step-by-step migration guide |
| CAD → 3DGS | No coverage | 40+ method conversion pipeline |
| Patent filing | Manual from scratch | Auto-generated claims & specs |
Live Demo
Try the Interactive Method Explorer →
Search 900 Methods instantly, filter by category, sort by citations, click any method card for details.
Integrations
This repo ships as both AI agent skills and an MCP server, so it works across agent runtimes and MCP clients:
| Client | How to use |
|---|---|
| DSH (DeepSeek Harness) | dsh plugin --profile web add jaccen/Awesome-Gaussian-Skills — the 15 skills + MCP renderer auto-mount via cordis.patch.yml |
| Claude Code / OpenClaw | skills load directly from skills/ (see CLAUDE.md); MCP server via the config below |
| Claude Desktop / Cursor / Cline | copy the MCP stdio config from .marketplace/mcp-servers/client-configs.md |
| Any MCP client | command: node, args: [/path/to/mcp-server/dist/index.js], transport: stdio (21 core tools) |
The MCP server exposes 21 tools (import_scene, set_camera, modify_gaussians, render_frame, sculpt_pipeline, SLAT latent editing, …) — see mcp-server/README.md and .marketplace/mcp-servers/mcp-metadata.json.
📖 Online Book: Spatial & Embodied Intelligence (New!)
** NEW (Jul 2026)** —A full open-source technical book, built around 3D Gaussian Splatting as the spine and weaving together spatial intelligence and embodied intelligence into one closed loop: representation → perception → planning → action.
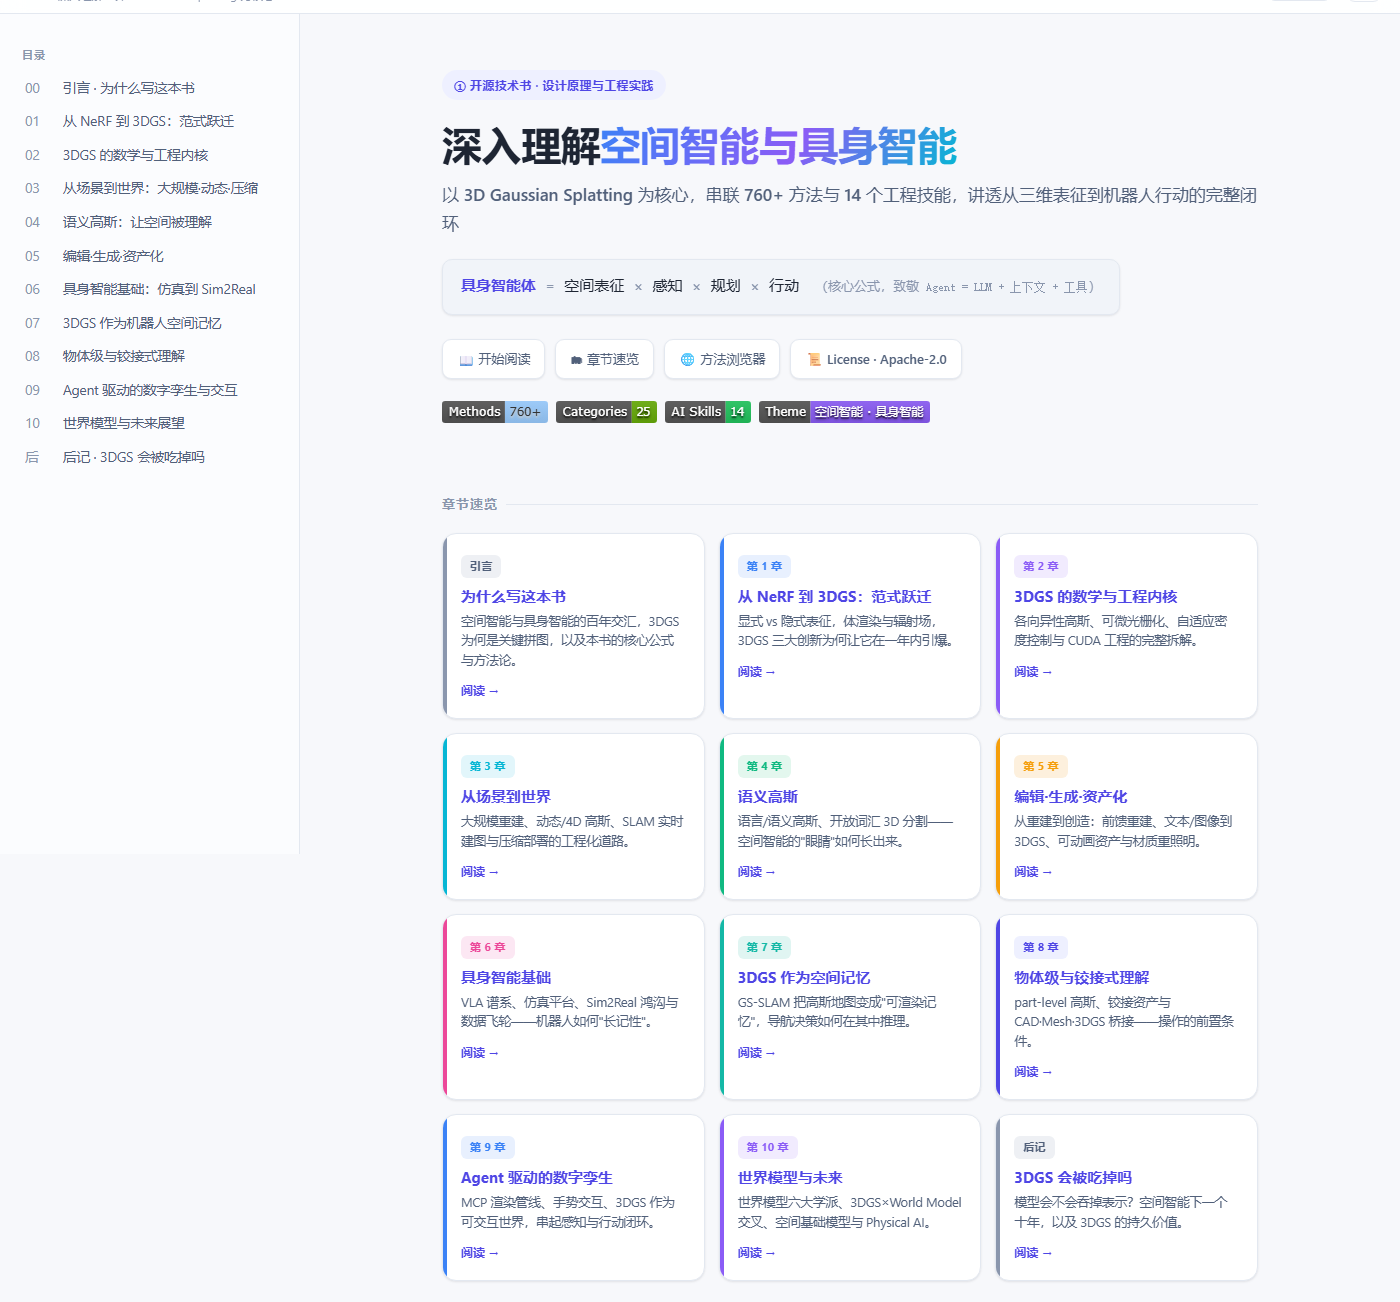
Core formula (echoing Agent = LLM + Context + Tools):
Embodied Agent = Spatial Representation × Perception × Planning × Action
What's inside — 13 chapters + hands-on prelude & capture SOP, every method name anchored to this repo's real data (900 Methods, 23 categories, 15 skills), zero fabrication:
| # | Chapter | Focus |
|---|---|---|
| 引言 | Why this book | Why 3DGS is the key puzzle piece of Physical AI |
| 前 | Landing prelude: should you, can you | Tech-selection matrix, eight cases where you should NOT use 3DGS, three reading paths |
| CH 01 | NeRF → 3DGS: A paradigm leap | Explicit vs implicit, the three innovations, the alpha-compositing formula |
| CH 02 | The math & engineering core | Anisotropic Gaussians, differentiable rasterization, adaptive density control, CUDA |
| 操 | Data-capture SOP | Device selection, trajectory design, seven exposure hard rules, scale calibration —the first step that decides your quality ceiling |
| CH 03 | From scene to world | Large-scale, dynamic/4D, GS-SLAM, compression & deployment |
| CH 04 | Semantic Gaussians | CLIP/DINO feature distillation, open-vocabulary 3D segmentation |
| CH 05 | Editing · Generation · Asset-ization | Feed-forward reconstruction, SDS generation, animatable assets, PBR relighting |
| CH 06 | Embodied intelligence basics | VLA lineage (RT/π0/GR00T/ReconVLA), simulation, Sim2Real |
| CH 07 | 3DGS as robot spatial memory | GS-SLAM, map-as-renderer, three tiers of spatial memory |
| CH 08 | Object-level & articulated understanding | Part-level Gaussians, URDF bridging, the CAD·Mesh·3DGS triangle |
| CH 09 | Agent-driven digital twins | MCP rendering pipeline, gesture interaction, the perception-action loop |
| CH 10 | World models & the future | Six schools of world models, 3DGS×World Model, spatial foundation models, Physical AI |
| CH 11 | Security, provenance & copyright | 3DGS watermarking, GaussTrace forensics, adversarial attacks, IP management |
| CH 12 | Capture-to-delivery: the end-to-end pipeline | Ten-stage tool selection & pitfalls, formats & coordinate systems, cost/duration estimates, project failure modes |
| CH 13 | Industry playbooks: six verticals | Museums & tourism, e-commerce, industrial inspection, AD simulation, embodied robots, surveying & mapping |
| 附 | Appendix | Datasets, evaluation metrics, delivery-metric conversion & acceptance-report templates |
| 实 | Practice index: from book to engineering | 15 engineering skills · 34 MCP tools · 900+ method explorer, chapter-to-runnable-resource mapping |
| 后记 | Will 3DGS be eaten? | Why explicit representations will be compressed, not consumed |
Each chapter ends with hands-on exercises and links back to the repo's method tables, references/, and skills —so reading the book and doing the engineering are one seamless flow.
Highlights you won't find in a paper list:
- The six schools of world models (2026 taxonomy) and where 3DGS sits as the only representation that is simultaneously renderable, differentiable, and editable.
- How
GS-World,ManiGaussian, andOrbiSimturn 3DGS into a differentiable simulation engine. - A three-tier model of robot spatial memory (geometric → appearance → semantic) and where current GS-SLAM actually stands.
Why we wrote it (and how it relates to this repo)
This book is the narrative layer over the repo's data layer. The repo gives you 900 method names, abstracts, and 15 engineering skills —but not the through-line that connects them. The book supplies that through-line: it argues why 3DGS became the bridge between spatial intelligence and embodied intelligence, and walks every chapter back to concrete methods and skills you can use today. Read the book to understand the map; use the repo to ship the territory.
What's New (Oct 2026)
Latest Update (Oct 20, 2026): v0.9.8 — World Models Category Reinforcement (896 → 900) ⭐
Targeted reinforcement of the thinnest category. 4 new arXiv-verified 3DGS-based World
Model / Spatial Intelligence methods admitted, taking the library from 896 to 900. The
World Models & Spatial Intelligence category grew from 8 → 12 methods:
HY-World 2.0, F3DGS (federated multi-agent world modeling), 4DGS-WAM (object-centric
world action model), Cloth-Splatting (3DGS cloth state estimation). Two missing arXiv IDs
backfilled (Holi-Spatial → 2603.07660, Spatial-TTT → 2603.12255); two entries flagged
unverified pending source check (APEIRIA, S²AM3D). GSMem found already in library
under Embodied AI & Robotics — not duplicated. See changelog.
Previous Update (Oct 12, 2026): v0.9.7 — Manual Admission: 15 New Methods (881 → 896) ⭐
Manual admission of 15 new arXiv-verified 3DGS methods, taking the library from
881 to 896 (+15, +1.7%). Admissions span 9 categories: Acceleration (H2-Ray, TileSkipper,
SplatQ), Feed-Forward (CompactSplat, DeltaSplat, DensiTok), Embodied AI & Robotics
(Splat2Act, 2DGS-Planner, NovaSplat), plus OuroWorld (Dynamic & 4D), PAM-ToD (HDR & Relighting),
FlyMark (Security), GSCV (Compression & Streaming), OpenSplatGraph (Language & Semantic),
PCAsplat (Surface & Rendering). Every admitted method name is self-stated in its own paper's
title/abstract (R9 protocol) and arXiv-verified. 12 candidate papers were rejected for lacking a
self-stated method name, being benchmark-only, NeRF (not 3DGS), or using 3DGS merely as a tool. All data
carriers (methods.json / CSV / methods.html / abstracts.js / reference doc) re-verified at 896,
name sets compared entry by entry. No method name was fabricated.
See changelog/2026-10-12.md for the full admission list.
Update (Oct 7, 2026): v0.9.6 — Manual Admission: 9 New Methods (872 → 881) ⭐
Manual admission of 9 new arXiv-verified 3DGS methods, taking the library from
872 to 881 (+9, +1.0%). Admission includes Speedy-Splat (CVPR 2025, precise tile
intersection + efficient Hessian-based pruning, 6.71× render speedup) and 8 recent September 2026
papers: AESplat (pose-free feed-forward), AGILE-GS (anchor-guided NBV), OC-GS (irregular turntable),
ClearGS (handheld video), ChronoFuseGS (multi-temporal fusion, PG 2026), TangoGS (cross-scale
compact), RRTO-CF3DGS (COLMAP-free), Observation-Gram (SH compression).
All data carriers (methods.json / CSV / methods.html / abstracts.js / reference doc)
re-verified at 881, name sets compared entry by entry. No method name was fabricated.
See changelog/2026-10-07.md for the full admission list.
Update (Sep 21, 2026): v0.9.5 — Daily arXiv Scan: 13 New Methods (859 → 872) ⭐
Routine daily arXiv scan admitted 13 new arXiv-verified 3DGS methods, taking the library from
859 to 872 (+13, +1.5%). Admissions span Surface & Rendering, Feed-Forward, Large-Scale,
Compression, Sparse-View, Cross-Domain, Embodied AI & Robotics, Dynamic, and Language & Semantic
categories (incl. LiteTex-GS, GrapeSplat, VDGS, CRP-GS, NormLift). 7 candidate papers
were rejected for failing the verification protocol — benchmarks without a self-stated method name,
descriptive-only paper titles, or 3DGS used merely as a tool. All data carriers
(methods.json / CSV / methods.html / abstracts.js / reference doc) re-verified at 872,
name sets compared entry by entry. No method name was fabricated; the library's
"every entry arXiv-verifiable" guarantee holds.
See changelog/2026-09-21-v3.md for the full admission list.
Earlier updates (v0.9.4 and before)
Latest Update (Sep 21, 2026): v0.9.4 — Multi-Channel Harvest: 700 → 859 Methods + Accuracy Overhaul ⭐
Knowledge base expanded from 700 to 859 verified methods (+159, +22.7%) through a multi-channel arXiv
harvest over the last 150 days. Six query families (cs.CV / cs.GR / cs.RO / full-corpus /
abs:"3D Gaussian Splatting" / ti:"Gaussian Splatting") returned 395 candidates; after verification
162 were admitted. Also in this release:
- Verification protocol (R1–R6): every admission requires the paper's self-stated method name,
reproduced in its own abstract; multi-word names must contain a proper-noun token — this alone rejected
67 descriptions masquerading as method names (
Capacity-Controlled,Scene-Level). 114 borderline candidates were read individually; 25 adjudicated in, the rest dropped. - Accuracy repairs: 57 reference links had a displayed arXiv ID differing from the hyperlinked one
(all had the correct ID displayed, wrong link). 13 mis-attributed entries deleted — e.g.
Dynamic 3D Gaussianspointed at 2309.13114, which is actually a magnetic spin-glass physics paper, andGS-LRM-v2pointed at DOF-GS. All now verified against the arXiv API. - AIGC traces removed from 29 text files; 21 historically corrupted JPEGs restored and re-stripped safely.
README_CN.mdrecovered from double-encoding corruption that had mangled every Chinese string.- Full carrier sync —
methods.json/ CSV /methods.html/abstracts.js/ reference doc all verified at 881, name sets compared entry by entry rather than by count alone.
Adjudication wave (same day). A second pass resolved every name carrying a derived suffix or
colliding with another entry: Scaffold-GS+ and GaussianSplatting-SLAM-v2 deleted (no such paper
exists), Luminance-GS++ renamed to its self-declared base name, and Spark 2.0's description
corrected — it is World Labs' open-source WebGL2 splat renderer, not an NVIDIA robotics simulator.
Two independent papers both self-name GeoGS-SLAM (2607.07452 and 2607.11184, disjoint author lists);
they are two methods, not a sequel, and are now disambiguated. 862 → 859.
See changelog/2026-09-21.md and changelog/2026-09-21-v2.md for the full audit trail.
Latest update (Sep 20): v0.9.2 —Scene Agent + Mapmost Engineering Wave: 5 New Methods + 6 Skill Enhancements. Knowledge base expanded from 692→ 97 methods. Added 5 scene-generation Agent papers: SceneSmith (ICML 2026 Spotlight, MIT CSAIL —hierarchical designer-critic-orchestrator VLM agents for simulation-ready indoor scenes), Scenethesis (ICLR 2026, NVIDIA —training-free LLM+vision agentic framework), SceneGenAgent (ACL 2025 —LLM coding agent for industrial scenes), SceneConductor (arXiv —multi-agent orchestration from single image), SceneAssistant (arXiv —visual-feedback agent for open-vocabulary scene generation). Injected Mapmost production engineering knowledge into 4 skill files: 3DGS individualization (单体化) in best-practices.md, LOD streaming + seam-fix + adaptive partition training in best-practices.md, 3DGS+3DTiles multi-source fusion in gis-toolchain.md, LUT color grading in tech-stack.md, Mapmost as Digital Twin player with 100km² benchmark in industry-landscape.md. Categories updated: Generation +4, Embodied AI & Robotics +1.
Previous (Sep 20): v0.9.1 —ECCV 2026 Wave: 14 New Methods. Knowledge base expanded from 678→ 92 methods. All 14 new entries arXiv-verified or ECCV-official: Wat3R (underwater 3D geometry without annotations), GeoNVS (geometry-grounded video diffusion with GS-Adapter), Edit3r (instant 3D editing from unposed images), SA-ResGS (first residual learning for 3DGS in next-best-view selection), GaussianLens (on-demand localized high-res reconstruction), Deformable Triangle Splatting (non-convex primitive with per-edge control points), Neural Harmonic Textures (per-primitive harmonic feature decoding), CubicSplat (error-bounded differentiable vector graphics), TetraSDF (analytic isosurface extraction), Heat Kernel Textures (ECCV 2026 Best Paper —geodesic Gaussians), **GR